Gear Ratio Tuning – Speed vs Torque Explained (What I Learned After Making Every Gearing Mistake Possible)
Gear Ratio Tuning – Speed vs Torque Explained.
When I bought my first hobby-grade RC car, I thought more speed was always better.
So naturally, the first thing I did was start changing gears.
I went online, watched a few videos, installed a larger pinion gear, and expected my RC truck to become an absolute rocket.
Instead, it got slower.
The motor ran hotter. The battery drained faster. And after one weekend, I was standing in my driveway wondering how I had managed to spend money to make my RC car perform worse.
Looking back, that was the moment I realized something most beginners don’t understand right away: gear ratio tuning can have a bigger impact on performance than many upgrades people spend hundreds of dollars on.
In my opinion, gearing is one of the most overlooked aspects of the RC hobby. Once I started understanding how it worked, I stopped chasing random upgrades and started building RC cars that actually felt better to drive.
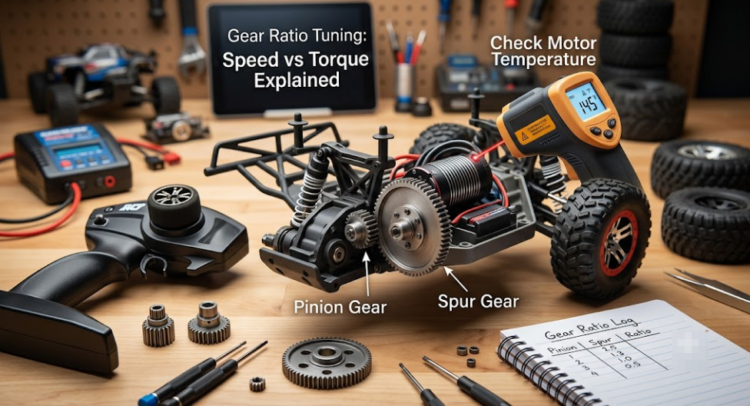
What Is a Gear Ratio?
If you’re new to RC cars, don’t worry — I was confused by gear ratios at first too.
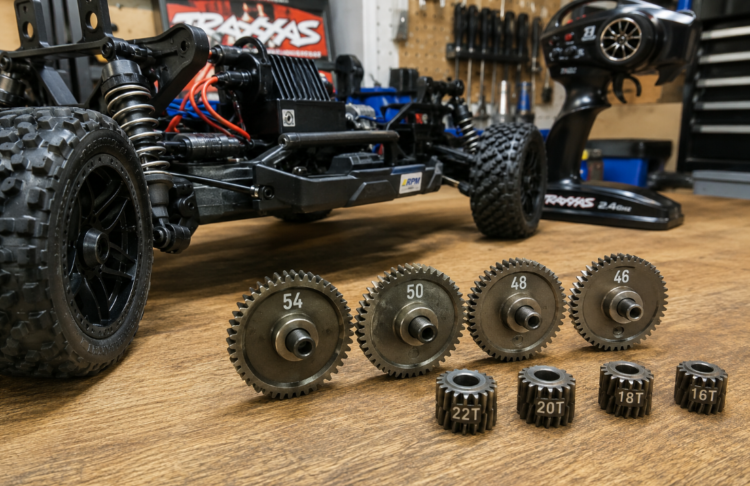
A gear ratio simply determines how power from the motor gets transferred to the wheels. It’s calculated by dividing the number of teeth on the spur gear by the number of teeth on the pinion gear (spur teeth ÷ pinion teeth = final drive ratio).
Think about riding a bicycle. When you’re climbing a steep hill, you shift into an easier gear because it gives you more leverage. You don’t move as fast, but pedaling becomes much easier. The exact same principle applies to RC cars.
A gearing setup can favor acceleration and pulling power, or it can favor top speed. The trick is finding the right balance.
A quick real-world reference from my own gearing notebook:
| Pinion (T) | Spur (T) | Ratio | Feel |
|---|---|---|---|
| 19 | 87 | 4.58:1 | Strong torque, great for off-road/dirt |
| 21 | 87 | 4.14:1 | Balanced — my daily driving setup |
| 23 | 87 | 3.78:1 | Faster top end, needs open space |
These numbers will vary depending on your motor’s kV rating and your car’s final drive ratio, but they’re a good starting reference point if you’ve never logged your own setups before.
Why I Stopped Chasing Top Speed
For a long time, I thought the goal was simple: make the RC car as fast as possible. That sounds great until you actually drive it.
One of my early setups was geared aggressively for speed. On paper, it looked impressive. In reality, the truck felt sluggish leaving a stop, the motor got hotter than I was comfortable with, and unless I had a huge open parking lot, I rarely got anywhere near the maximum speed anyway.
That’s when I started realizing that usable performance matters more than bragging-right numbers. I also think this is where many beginners get frustrated — they spend money chasing speed while accidentally making their RC car less enjoyable to drive.
Understanding Torque vs Speed
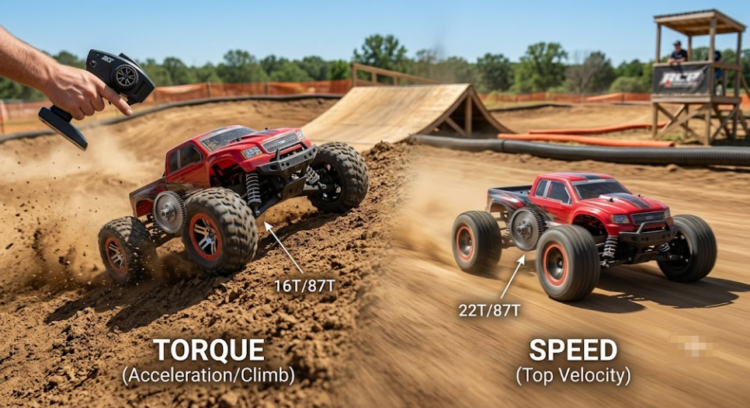
More Torque
When you gear for torque, your RC car gains stronger acceleration. You’ll notice:
- Faster launches
- Better hill climbing
- Improved off-road performance
- Less strain on the motor
This setup is especially useful if you drive on dirt, grass, gravel, or rough terrain. Most of my off-road trucks are geared slightly toward torque because I value responsiveness more than top speed.
More Speed
When you gear for speed, the wheels rotate more with each motor revolution, which can increase top speed under the right conditions. However, there’s always a trade-off — acceleration usually decreases, motor temperatures can rise, and battery efficiency often drops. If the gearing becomes too aggressive, the motor may struggle to reach its ideal operating range.
In my experience, many RC cars actually become slower in real-world driving when geared too heavily for speed.
The Biggest Mistake I Made
The biggest mistake wasn’t choosing the wrong gear ratio. It was changing multiple things at once.
I upgraded the motor. Installed different tires. Changed the battery. Adjusted gearing. Then I had absolutely no idea which modification was helping or hurting performance.
Now I make one change at a time and test thoroughly before moving on — usually running the same short track or straightaway and timing it, so I have an actual number to compare instead of just a “feeling.” That simple habit has saved me a lot of money and frustration.
Tire Size Changes Everything
This is something I wish someone had explained to me earlier: installing larger tires effectively changes your final gearing.
Many people add bigger tires because they look great, then wonder why acceleration suddenly feels weaker. The answer is simple — larger tires make the motor work harder, because the same gear ratio now has to turn a wheel with a bigger effective diameter. Whenever I increase tire size, I usually revisit gearing to keep performance balanced.
Watch Motor Temperatures
This is the habit that changed everything for me.
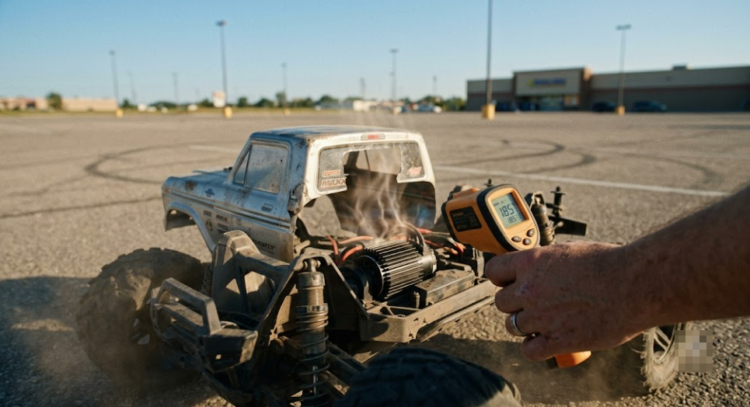
After every gearing adjustment, I check motor temperatures with an infrared thermometer. As a rough guideline, anything consistently over 160–180°F (70–82°C) right after a run is worth paying attention to — if it keeps climbing after every run, that’s usually a warning sign that the motor is working harder than it should.
I learned this lesson after nearly cooking a brushless motor during a summer speed-run session. Fortunately, I caught it early. Not everyone does. This is exactly the kind of overheating issue I break down in more detail — along with other common motor and drivetrain problems — in my RC car maintenance and troubleshooting guides.
How I Choose Gear Ratios Today
After years of experimenting, my approach is much simpler.
- For off-road driving: I lean slightly toward torque.
- For speed runs: I increase gearing carefully and monitor temperatures.
- For everyday driving: I aim for balance.
Honestly, balance usually wins. The fastest RC cars aren’t always the most enjoyable RC cars. The ones that accelerate well, stay cool, and remain predictable tend to get driven the most. I also feel that many hobbyists eventually reach the same conclusion after enough trial and error.
A Related Lesson-Gearing Can Affect Motor Health
One thing I didn’t realize early on is how closely gearing and motor health are connected. Many overheating problems that people blame on motors are actually caused by poor gearing choices. I’ve seen perfectly healthy motors run hot simply because the gearing was too aggressive.
If you’re experiencing overheating, loss of power, or inconsistent performance after a gearing change, it’s worth working through a proper diagnostic checklist rather than guessing. I keep an ongoing collection of real fixes for common RC car problems that covers several issues beginners often mistake for motor failure.
Quick Troubleshooting Checklist
If your RC car feels off after a gearing change, run through this before assuming the motor is bad:
- Check motor and ESC temperature immediately after a run
- Confirm the gear mesh isn’t too tight or too loose
- Re-check battery voltage under load
- Compare acceleration to your last known-good gearing setup
- Test on the same surface each time for a fair comparison
If there’s one thing I’ve learned from years of RC ownership, it’s that gear ratio tuning isn’t about finding the fastest setup — it’s about finding the right setup.
I used to think more speed automatically meant more fun. Now I know better. A well-balanced RC car that accelerates hard, stays cool, and feels predictable is far more enjoyable than a machine that’s constantly fighting its own setup.
In my opinion, gear ratio tuning is one of the most valuable skills any RC enthusiast can learn. Once you understand the relationship between speed and torque, you’ll make smarter upgrades, spend less money, and enjoy your RC cars a whole lot more.
And trust me, that’s a lesson I learned the expensive way.